TechCrunch AI · Published 2026-09-05
XDOF: turn real actions such as folding clothes into robot training data
People teleoperate robot arms or wear sensors while folding clothes. XDOF connects capture, processing and annotation to make those actions useful for robot training; funding talks provide the business background.
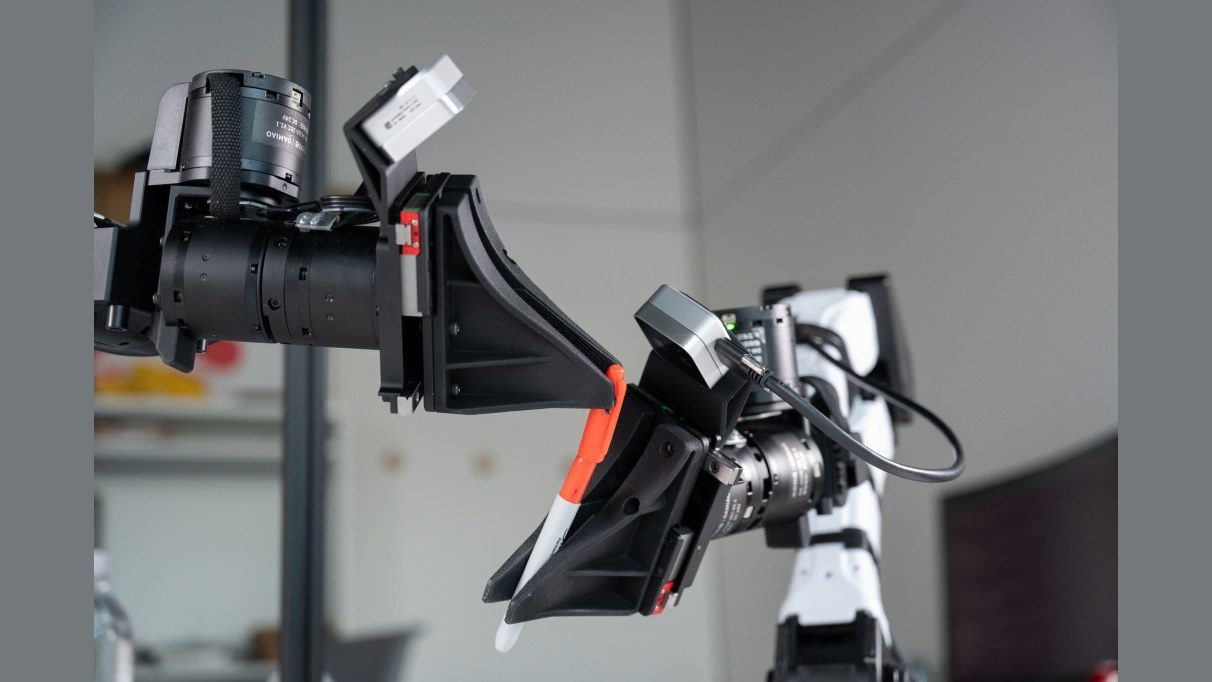
Turn physical actions into training material
XDOF builds collection tools, data pipelines and annotation systems. TechCrunch describes remote operation of robot arms and people wearing sensors while doing tasks such as folding clothes or flattening boxes.
This material comes from physical actions and device interactions rather than text on the internet alone. The report describes an ABC robotics dataset collaboration with Berkeley’s AI research lab and plans to expand collection teams across regions.
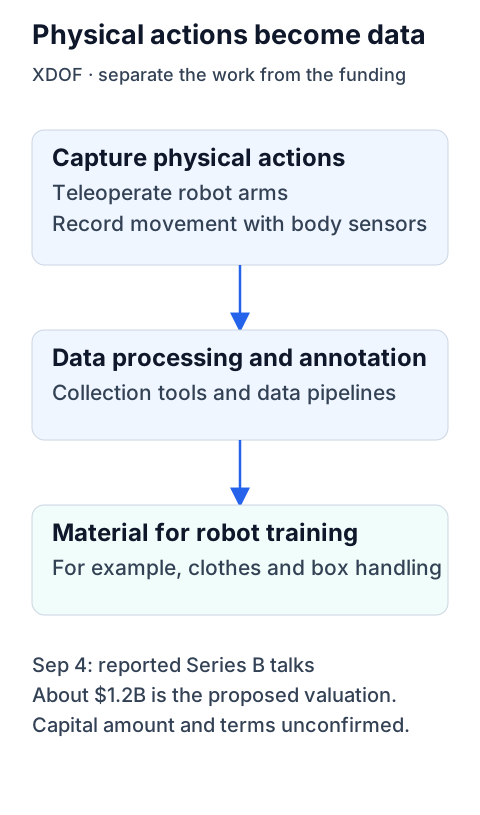
The $1.2B figure is a proposed valuation
The September 4 report cites people familiar with talks for an 8VC-led Series B at about a $1.2B valuation. XDOF had announced a $70M Series A in June. The new capital amount and whether the valuation includes it were unknown, and terms could change.
XDOF and 8VC had not responded to the report’s requests for comment. The figure describes reported funding talks, not money already raised.
Important additions and corrections
Dates below mark changes to our coverage.
- Addition ·
Added robot-data collection methods and clarified that $1.2B is a proposed valuation.
Sources and notes
sources中文
Sources and notes
- Read the originalTechCrunch AI
Retained summary and context
Collection provides an article link. Claims and citations require individual review. Collection is not proof of the claims or practical outcomes.
Sources and evidence · 2 links
Each link has a purpose and scope. Link counts do not establish independent confirmation; direct support applies only to the statements specified below.
This page keeps the original link and a short account. Follow the links below for the publisher’s full explanation.
Source timeline
- · Found this reading link via TechCrunch AI.
Collection record
First discovered: ; added to the library:
Collection and source publication have distinct dates.
Editorial record
Sources reviewed
· Beijing time (UTC+8)
Added robot-data collection methods and clarified that $1.2B is a proposed valuation. Original event, discovery and collection dates remain.
Sources and full record
This dates our review of the wording and sources, not a project release or product update.
Full record: before, after and sources (JSON)